Stress testing with 20000 Entities
When stress testing vsTASKER, simulating 20,000 entities is a heavy computational workload. The software is specifically built to handle massive sensor detection (like radar) while maintaining a smooth 30Hz frame rate. To achieve this, the simulation relies on key optimization techniques and built-in configurations:Proximity Mesh: Uses spatial hashing to group entities and prevent combinatorial explosion, allowing vsTASKER to efficiently manage clumping and movement logic for thousands of units.Batch Mode & Multi-threading: Maximizes CPU efficiency by executing heavy logic in batches, which is highly effective for testing swarm behaviors or large conflict scenarios.Sensor Filters: Limits active logic so units only process what they can actually detect in their environment, rather than calculating the state of all 20,000 entities globally every frame.Offloaded Visualization: Runs the simulation logic headless (or maps it in 2D) first to ensure maximum speed, delaying OpenSceneGraph (OSG) 3D rendering until algorithms are validated.If you are setting up a large simulation scenario, ensure you are testing against your hardware's limits by monitoring memory and CPU scaling to prevent engine stuttering.To help you set up and optimize your simulation, could you tell me:What type of entities are you simulating (e.g., infantry, drones, vehicles, aircraft)?Are you using any specific sensor or AI rules (like Radar or Game of Life) that require frequent updates?I can help tailor your vsTASKER configuration to prevent lag.
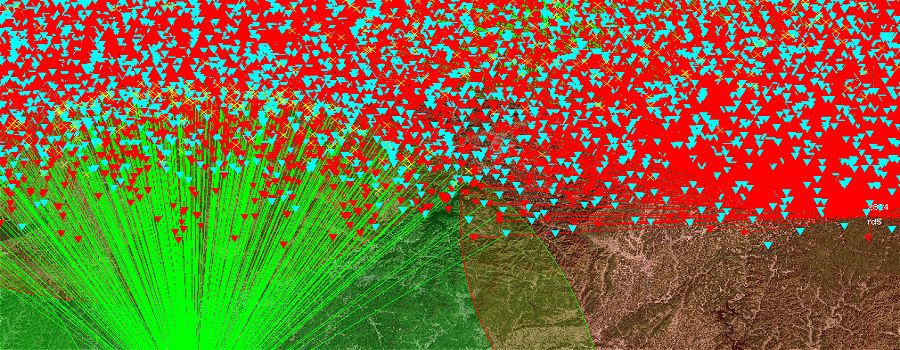
The "Stress testing with 20,000 Entities" exercise is a benchmark demonstration by VirtualSim for its wargaming and tactical simulation software, vsTASKER. The objective of this stress test is to prove that the simulation engine can handle a massive scale of concurrent entities while maintaining the industry-standard real-time performance threshold.Core Objectives & MetricsTarget Scale: Simulated and managed 20,000 active entities simultaneously.Performance Threshold: Maintained a stable 30Hz frame rate (30 frames per second) in real-time execution.Primary Challenge: Solving the combinatorial explosion where thousands of entities are querying, scanning, and interacting with each other concurrently, which typically degrades CPU performance exponentially.Technical Implementation & MethodsTo prevent the engine from collapsing under the weight of 20,000 × 20,000 possible interactions, VirtualSim utilizes specific optimization strategies:Massive Sensor Detection: The simulation tracks multiple complex sensor types (such as radar detection arrays and proximity grids) mapped onto all 20,000 entities.Proximity Mesh Optimization: Instead of performing global O(N²) checks for every entity against every other entity, vsTASKER employs a proximity mesh (spatial partitioning). This restricts sensor and collision logic only to entities sharing the same localized spatial cells.Batch Mode Execution: Employs optimized code execution models and memory-efficient batch loops to minimize thread overhead and maximize memory cache utilization.
Reference image showing features of vsTASKER
Reference video showing features of vsTASKER
Key Simulation DetailsvsTASKER uses specialized optimization techniques to prevent system lag and maintain performance under heavy loads:Sensor Optimization: Employs multiple sensor arrays and filters to selectively track and detect target entities without overloading the CPU.Proximity Meshes: Implements spatial indexing algorithms to efficiently handle the proximity and clumping behaviors of tens of thousands of moving particles.Logic Execution: Relies on event-driven behavior plans rather than continuous polling, conserving processing power.Technical PerformanceUpdate Rate: Maintains a smooth 30 Hz standard for synthetic environment processing and display.Data Handling: Capable of streaming and analyzing vast amounts of real-world or simulated data, such as worldwide ADS-B airline traffic.Code Generation: Converts complex graphical scenario plans into highly efficient C++ code for rapid execution.Use-Case ApplicationsThis level of stress testing translates to several highly demanding real-world simulations:Drone Swarms: Calculating optimal numbers for defensive or offensive autonomous drone swarms.Tactical Combat: Simulating dense, large-scale air, land, and naval battles across wide geographical areas.Mass Sensor Detection: Evaluating radar and sonar responses when multiple observers are pinging an area packed with targets
Downlaod Techical details - Stress testing with 20000 Entities
Request for Trial licence
Download User Guide & reference manual
Practical ApplicationsThis specific capabilities test establishes the baseline performance needed for complex simulation scenarios including:Drone Swarms: Managing vast numbers of autonomous unmanned systems executing coordinated attacks or defenses.Air Traffic & ADS-B Analysis: Simulating massive global or regional live air traffic routing networks.Large-Scale Wargaming: Simulating multi-domain (land, air, and maritime) battlefields featuring thousands of individual infantrymen, vehicles, and sensor nodes.Would you like to know more about the hardware requirements needed to run this benchmark, or details on how to set up spatial partitioning (proximity meshes) within the vsTASKER simulation suite?